Facilities
This page introduces the vehicles, the experiment room, and the apparatus used in our work. For what each theme is about, see the Research page.
-
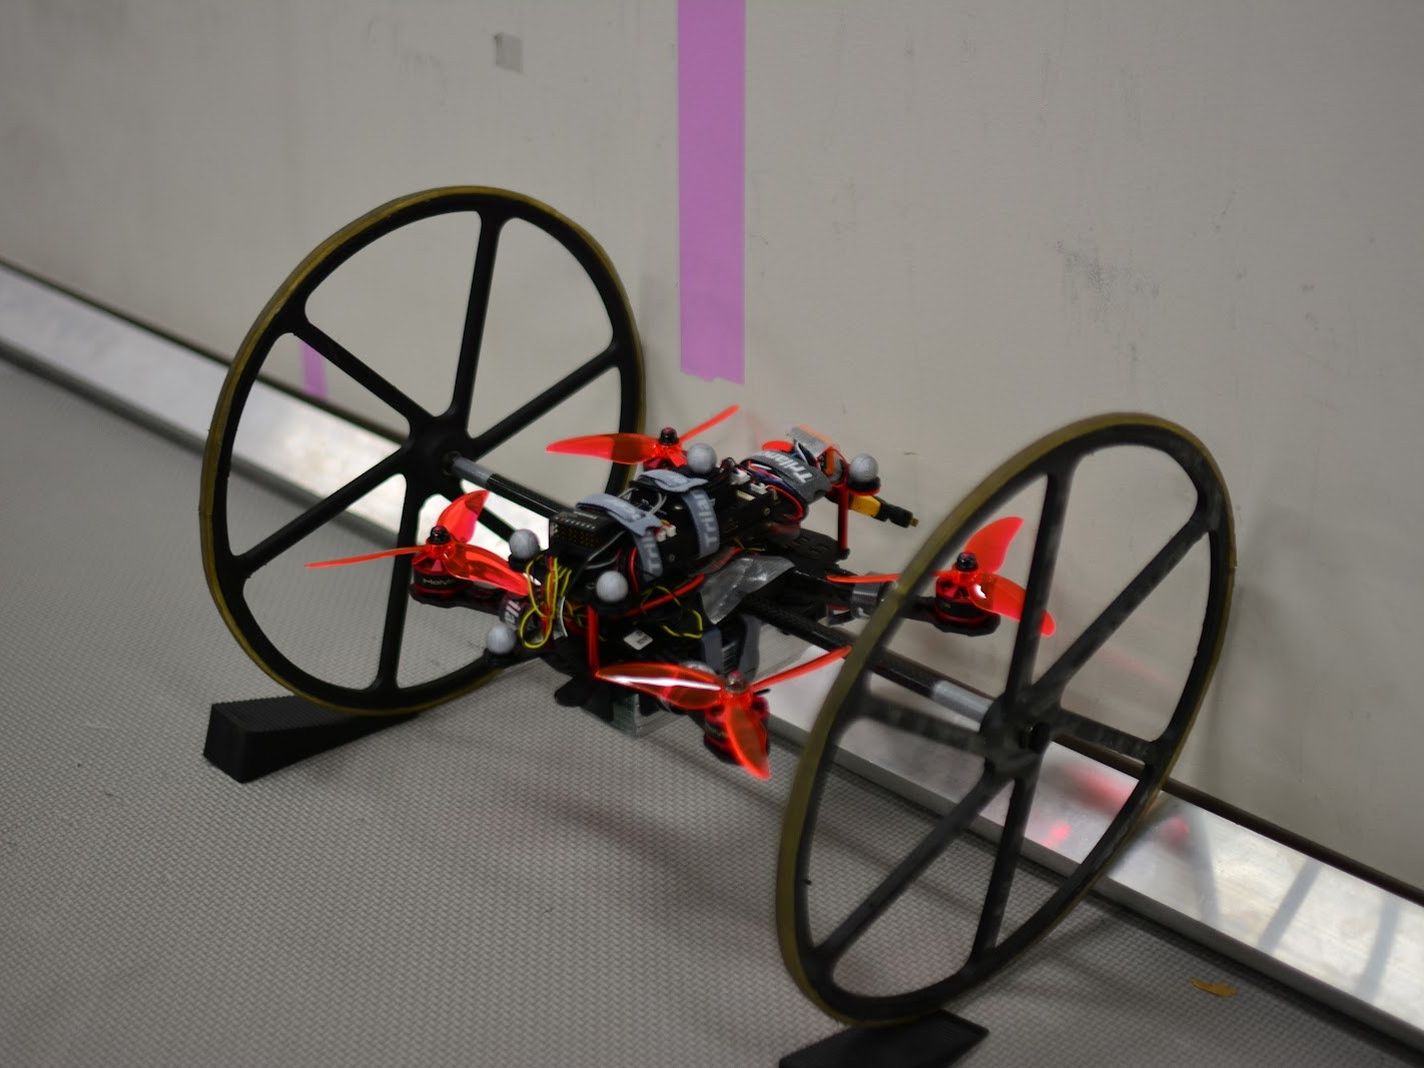
Wheeled drone
A drone with a wheel on each side. Pressed against a wall or ceiling, it travels on its wheels and holds its attitude close to walls and in narrow spaces.
-
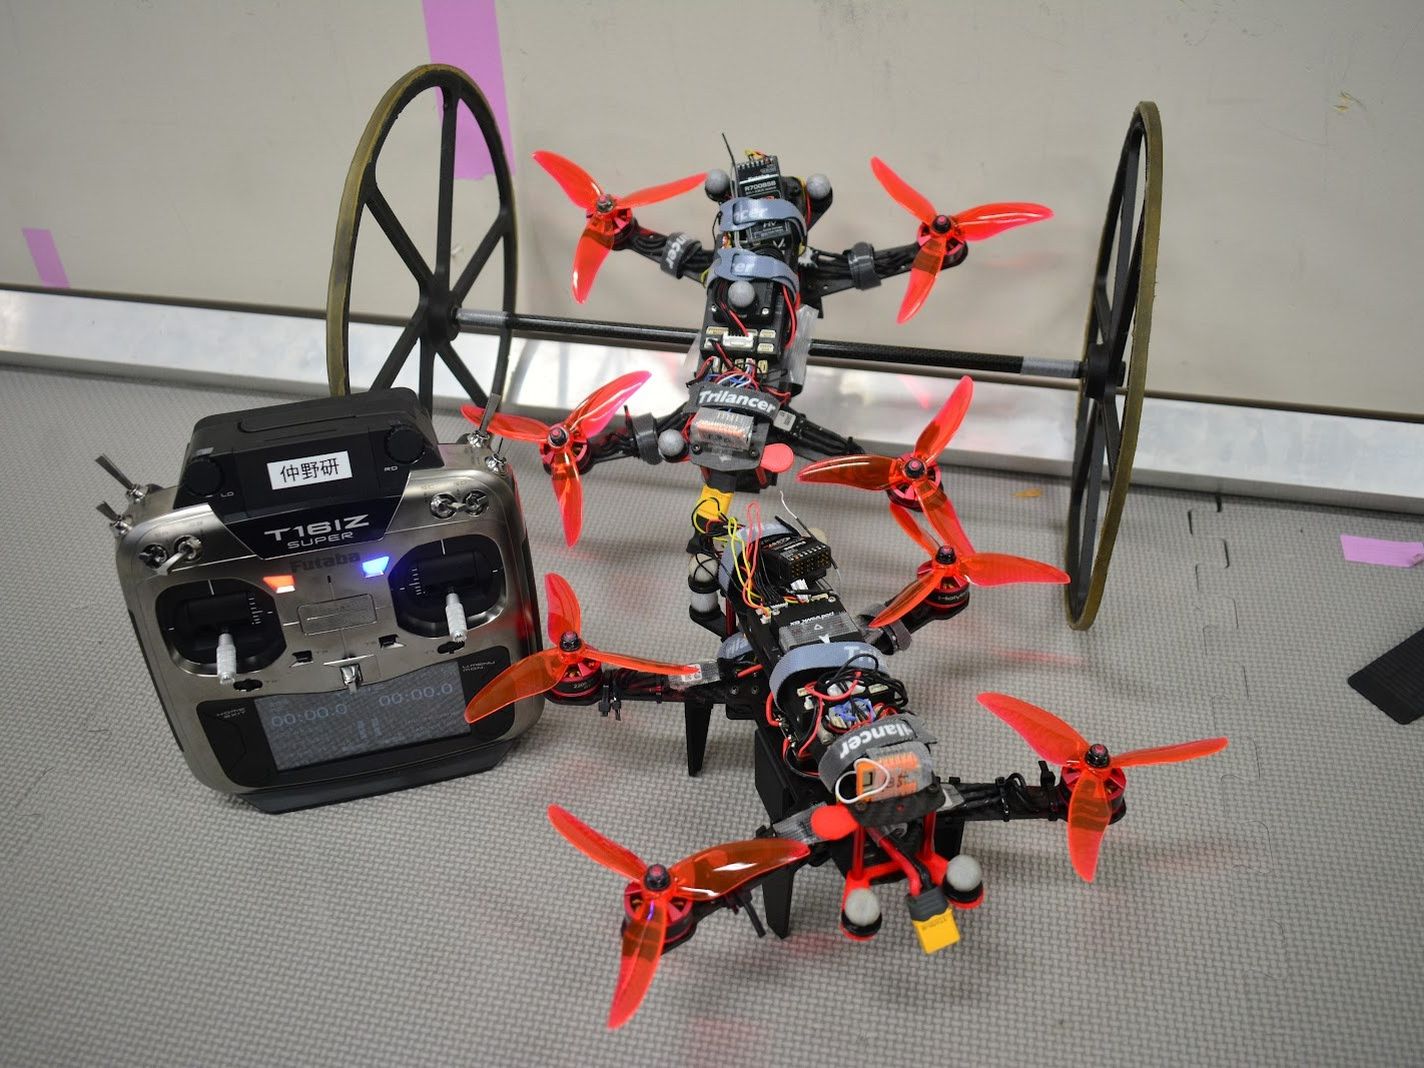
Research drones (QAV250)
QAV250-based drones used as the controlled vehicles. They fly with motion-capture markers attached.
-
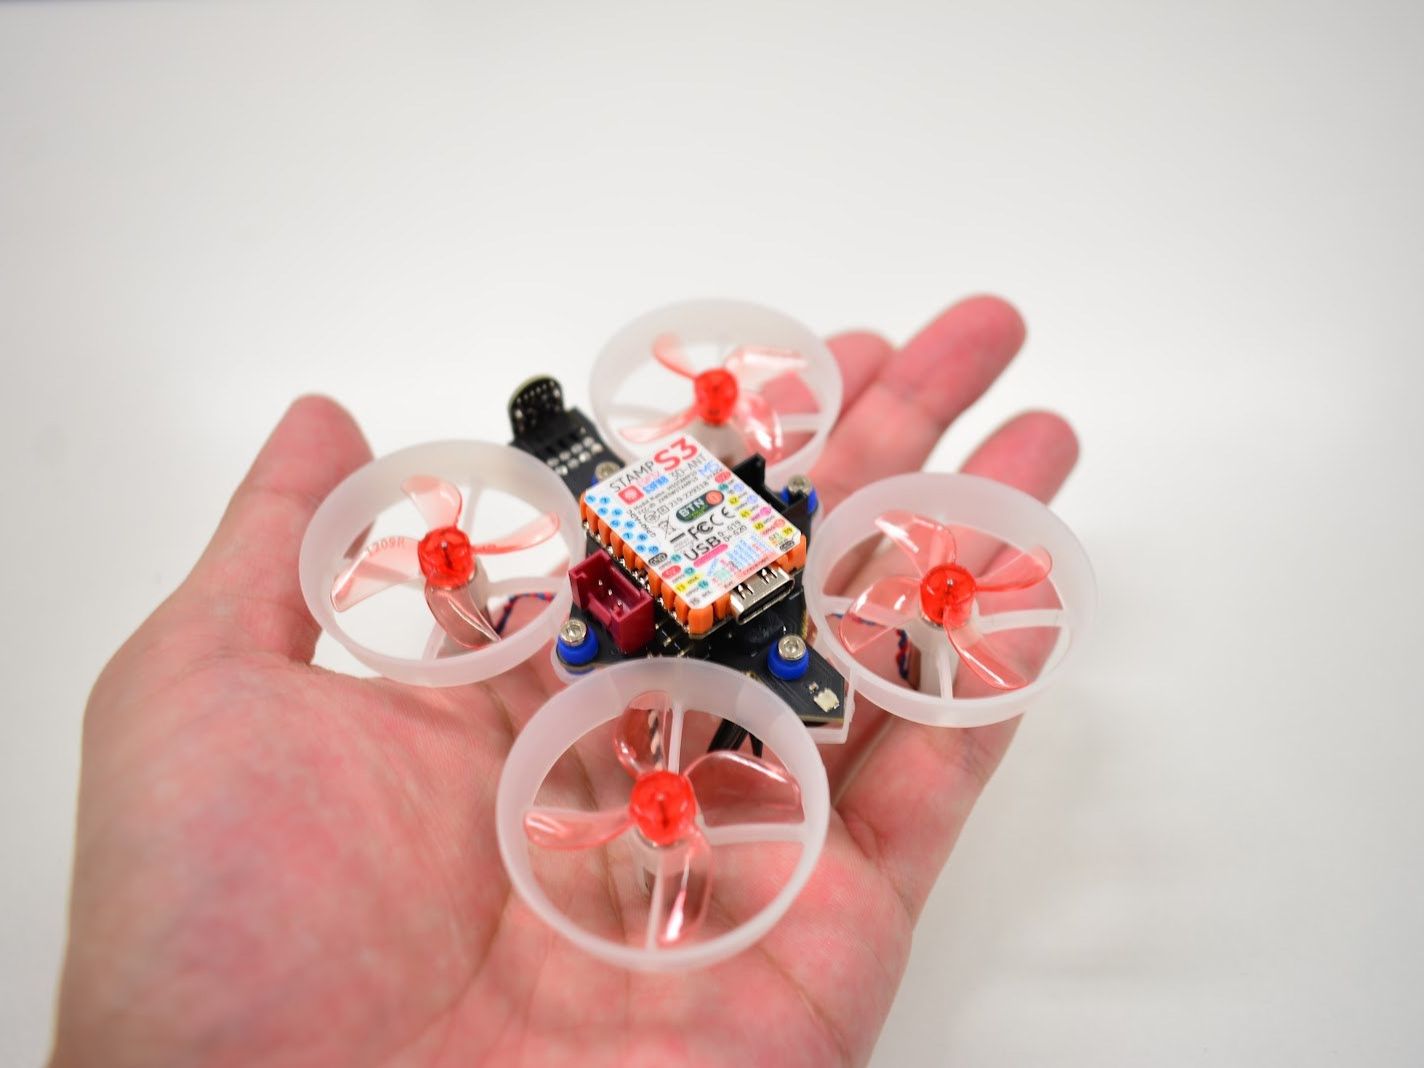
Small drone (StampFly)
StampFly, a small drone weighing about 37 g. It fits in the palm of a hand and is used for indoor experiments.
-
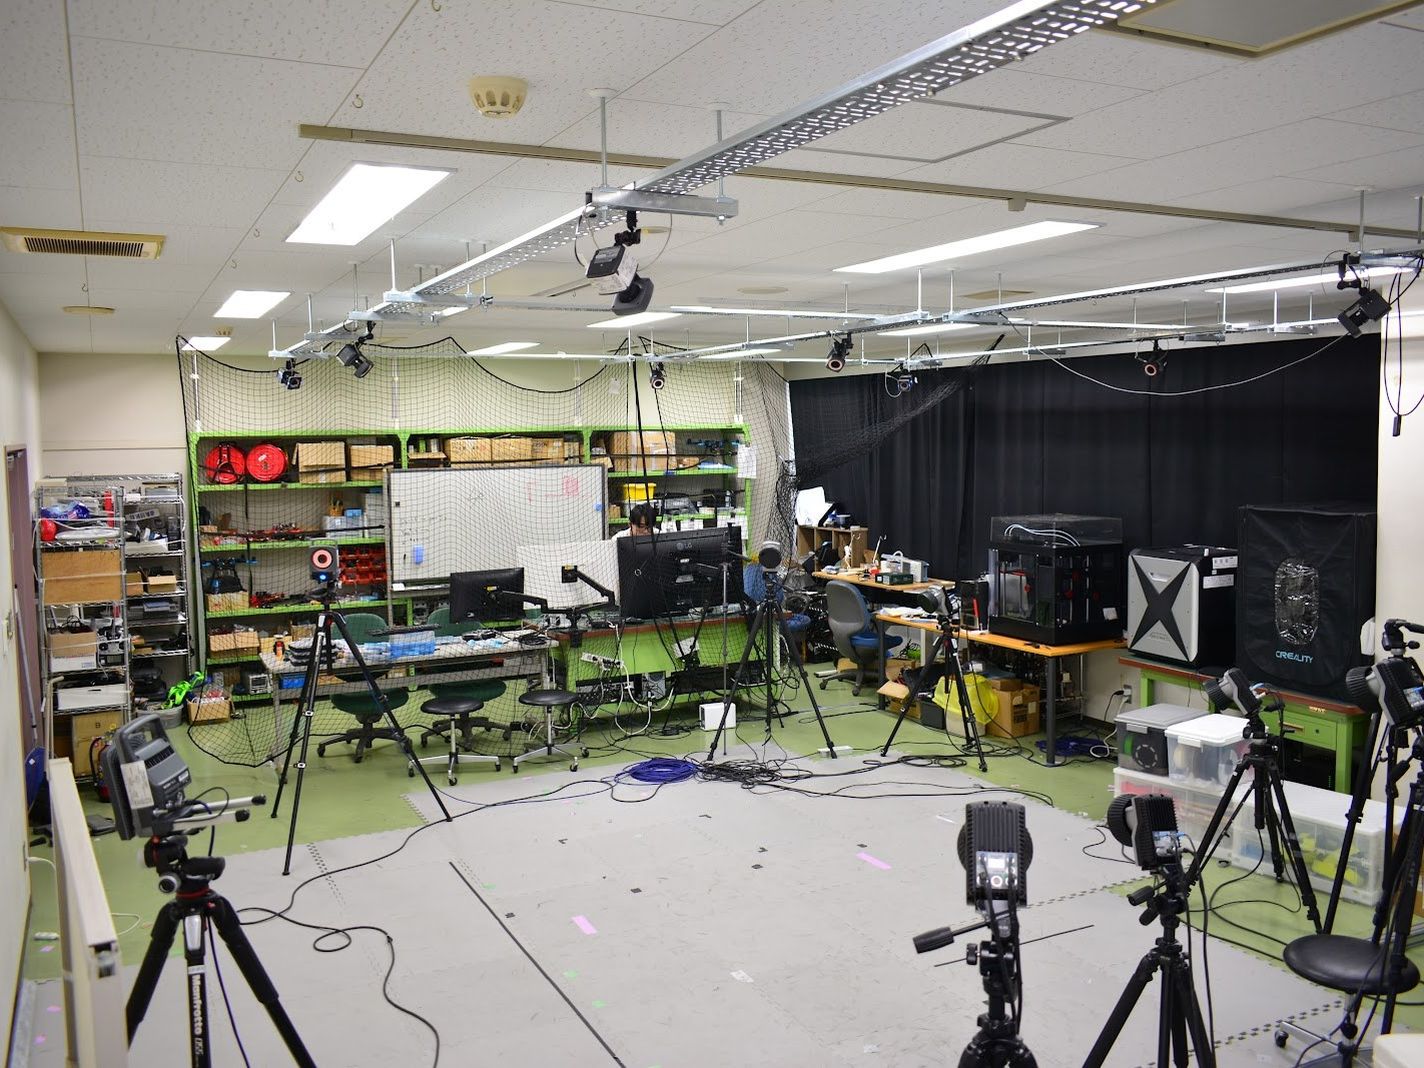
Experiment room
The experiment room shared with the Yamada Laboratory. It is equipped with motion-capture cameras and is where the drones fly.
-
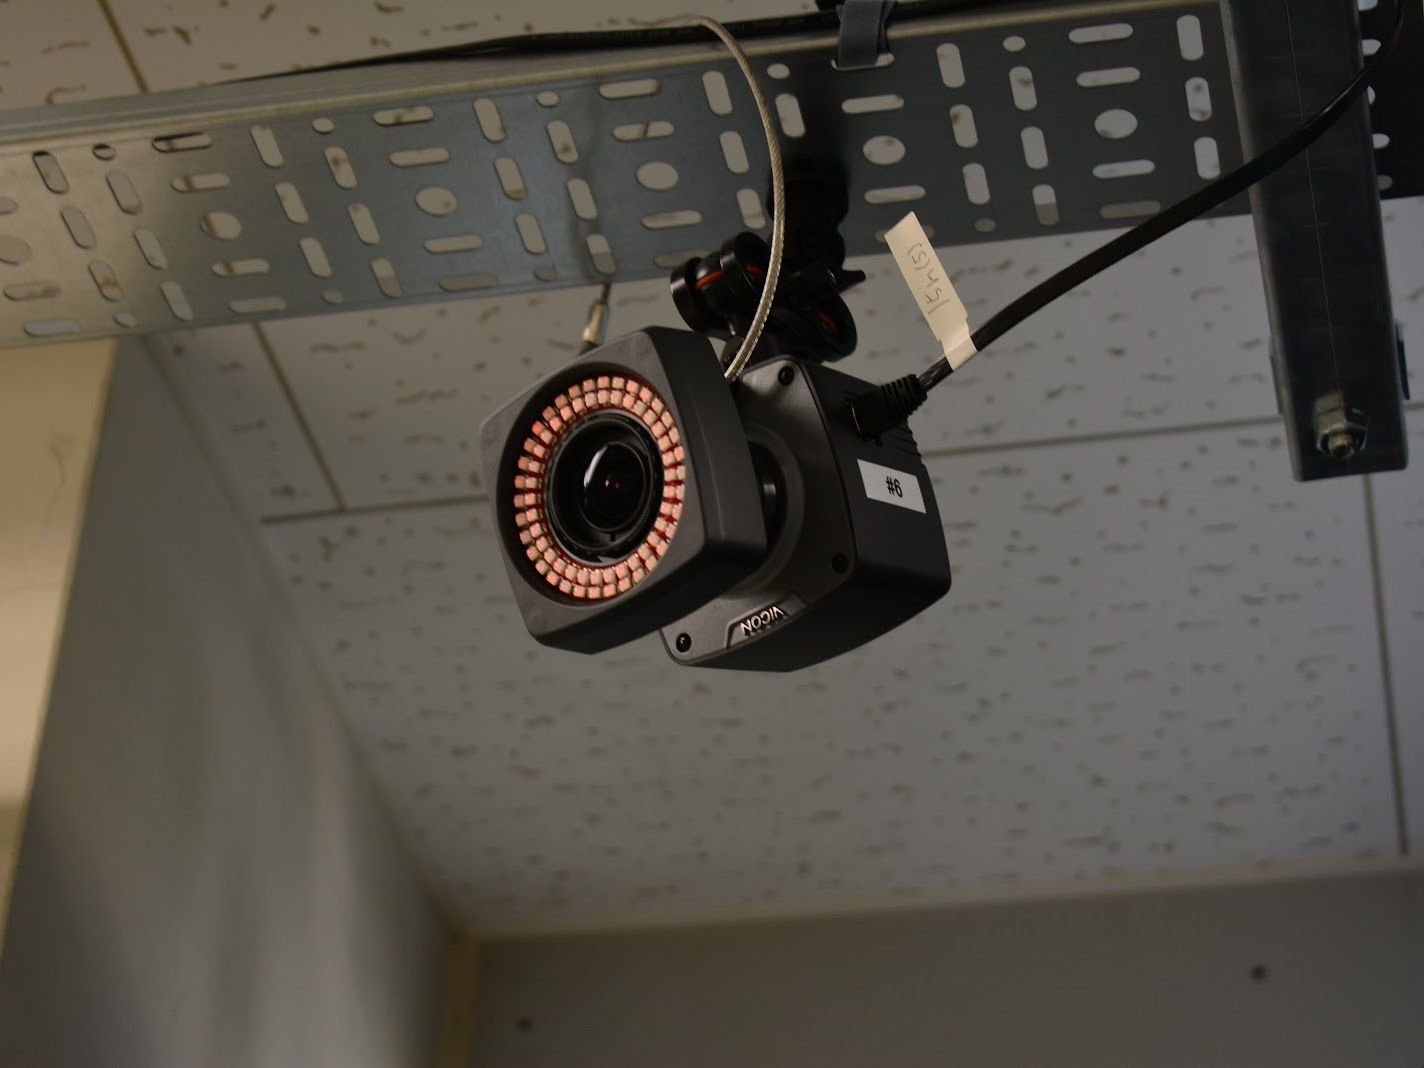
Motion capture
Two motion-capture systems, Vicon and Qualisys, are used depending on the experiment. They measure the position and attitude of the vehicles for control.
-
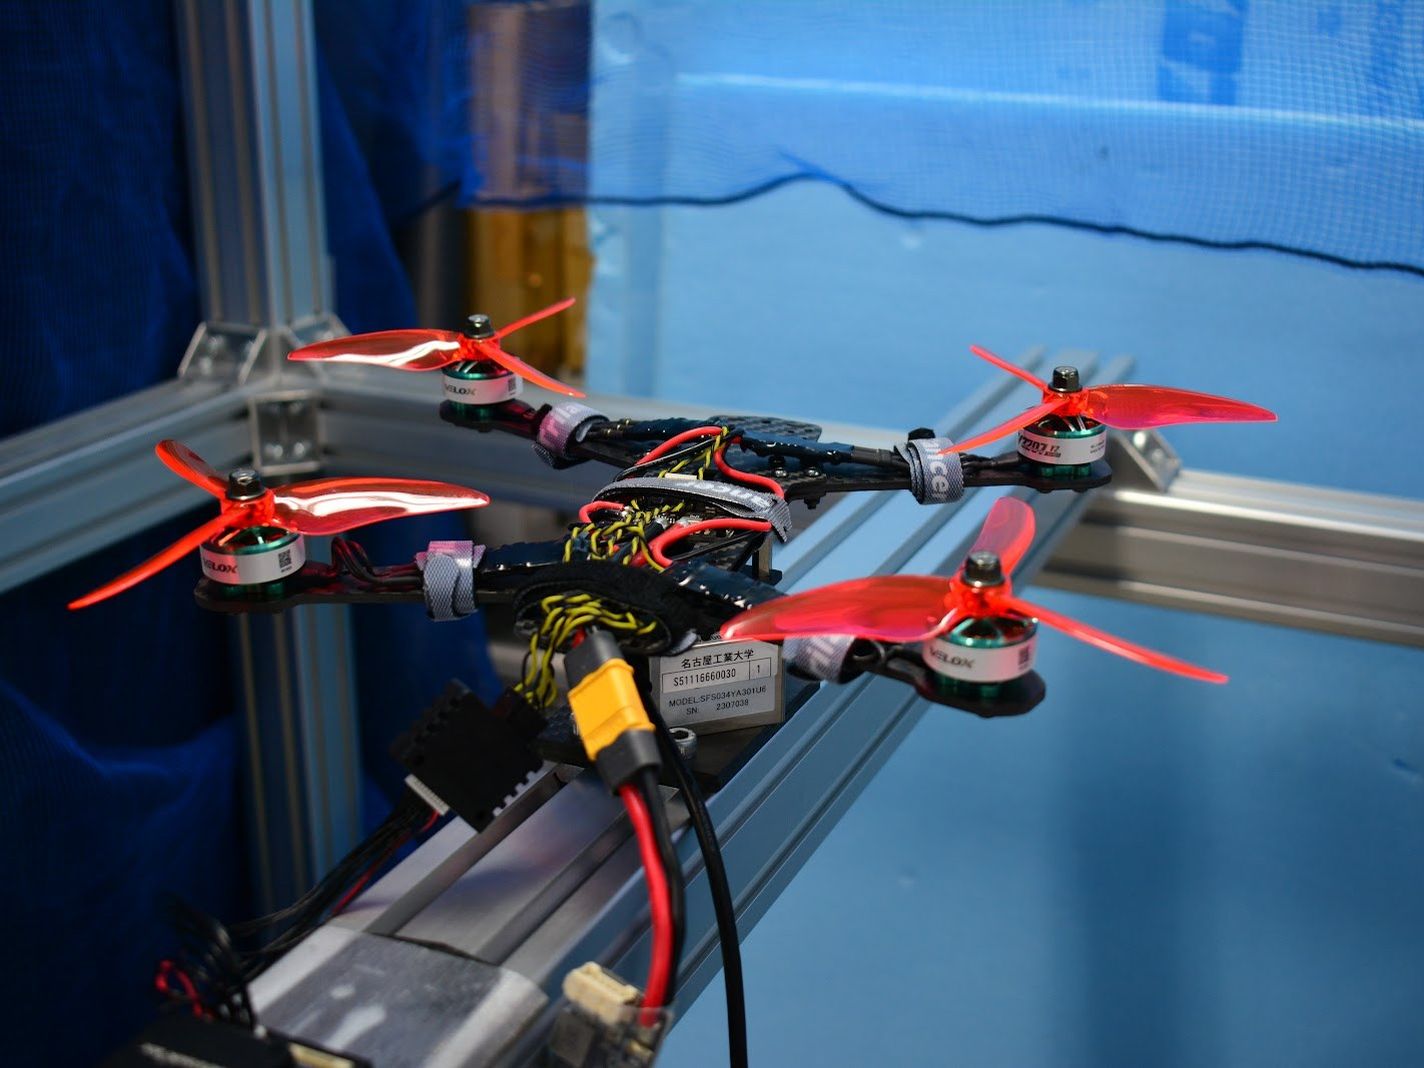
Thrust test stand
A stand that measures rotor thrust and reaction torque against voltage and current, using a Leptrino force sensor.
-
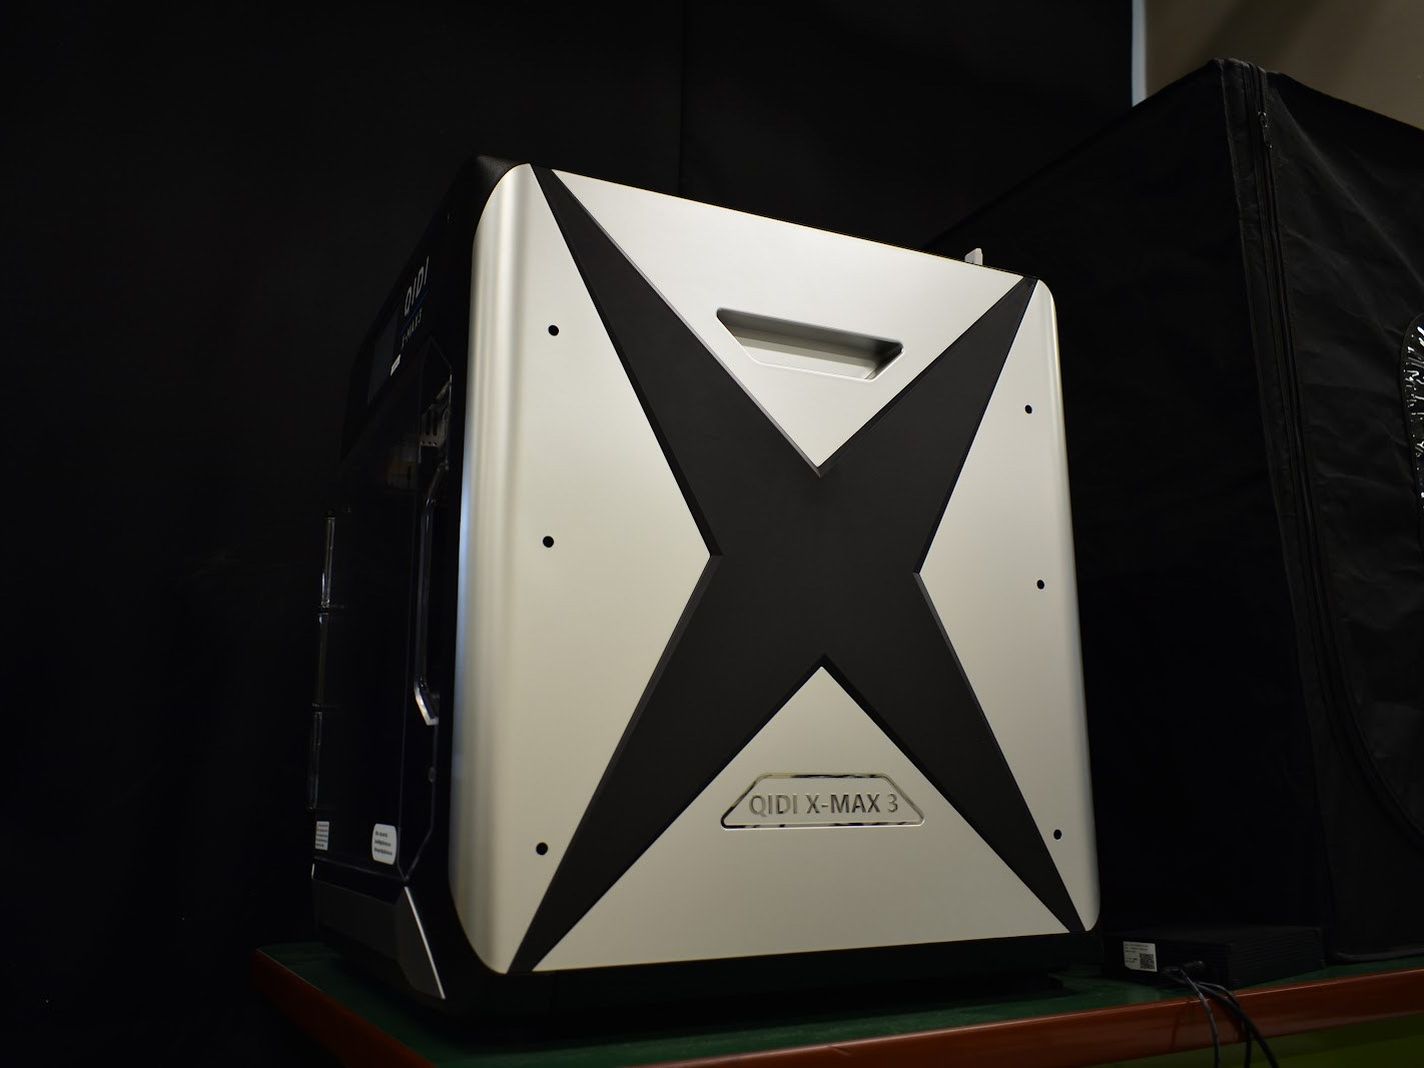
3D printers
3D printers for making airframe parts. Three machines are used according to the job.
We also have a testbed for wall running and hammering inspection, a haptic teleoperation setup, and an attitude-control test rig. Photographs of these will follow.
Simulator
Alongside the hardware, we develop and publish a MuJoCo simulator, with a demo that runs in your browser.
Other photographs
Photographs of lab activities and everyday life are posted on our external album, the GDAC Lab Blog (in Japanese). The group photo is on the People page.