GDAC Lab
This is the site of the Geometric Dynamics, Autonomy, and Control Laboratory (GDAC Lab) at Nagoya Institute of Technology, led by Satoshi Nakano. We hope it is useful for prospective students, colleagues in academia and industry, and anyone interested in control theory, robotics, and safety-critical systems.
Our work combines theory and hardware experiments on constrained control of rotational motion, geometric attitude control on SO(3), and applications such as wheeled drones for infrastructure inspection. A concise overview is on the Research page.
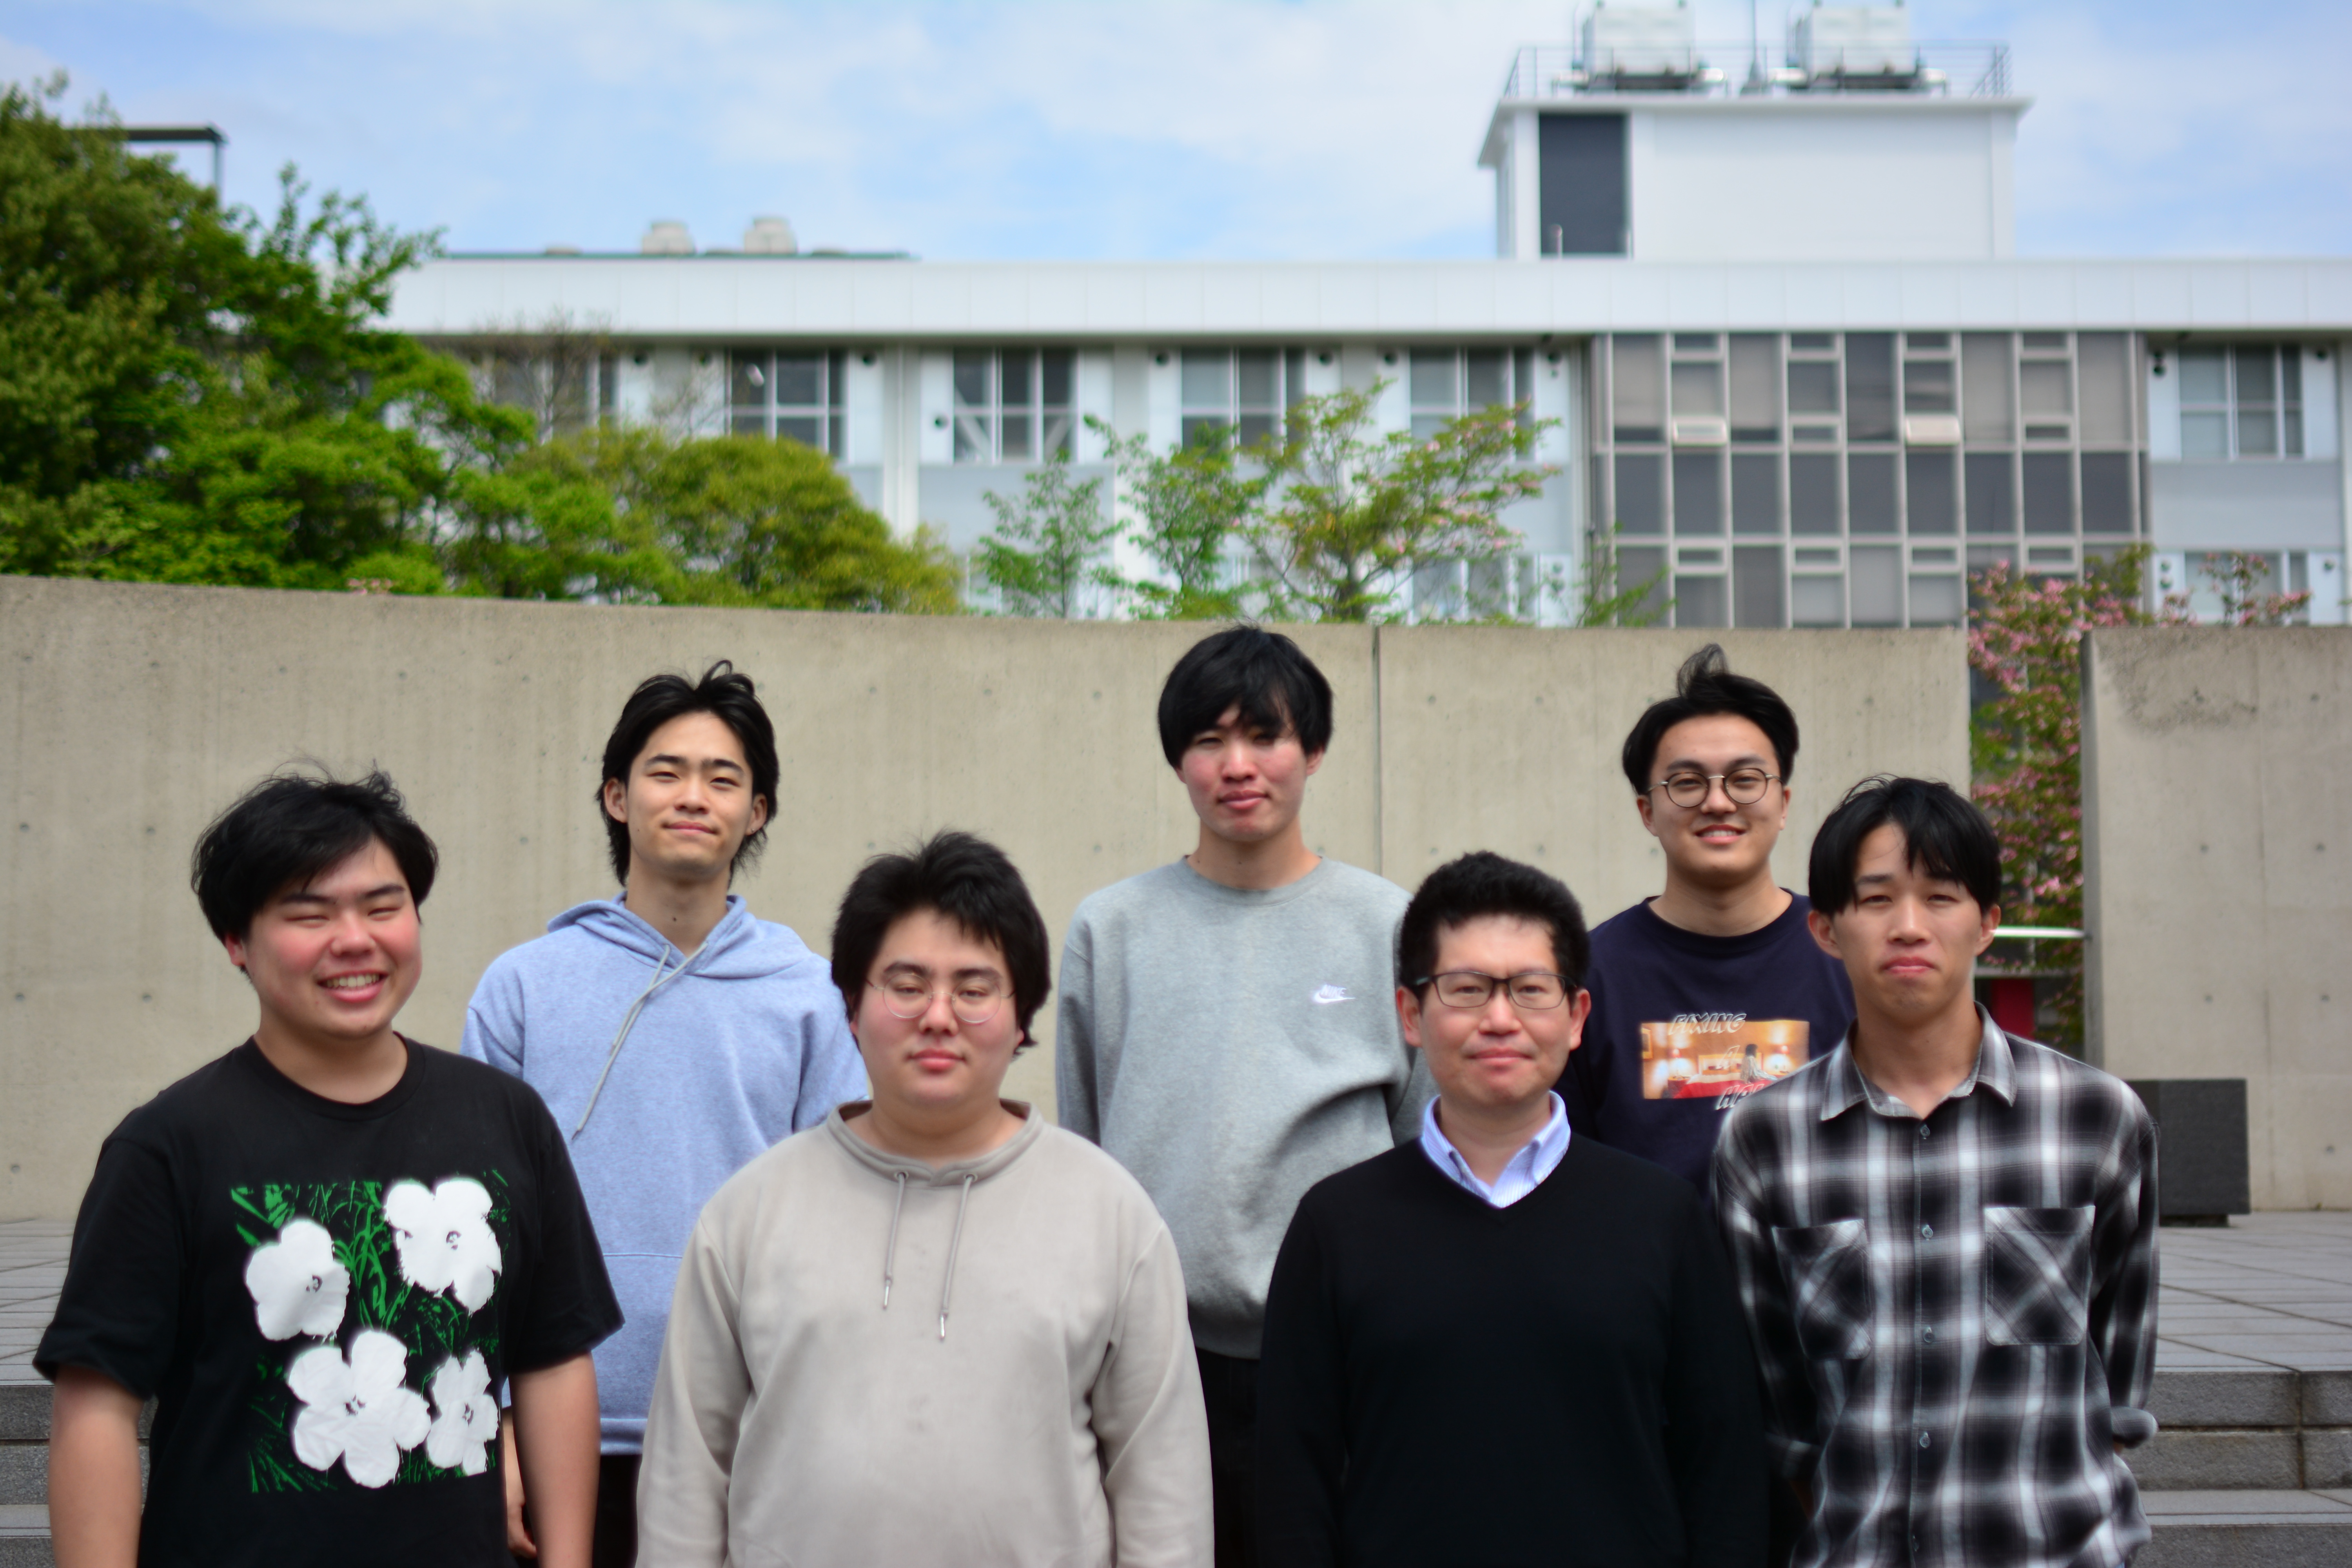
Photo gallery
On this site
- Research — themes and directions
- How the lab works — supervision, day-to-day life, visits and contact
- People — faculty, students, and collaborators
- Facilities — vehicles, the experiment room, and apparatus
- Simulator — our public simulator, running in your browser
- Attitude control with a keep-out direction — a spacecraft turning without pointing its camera at the Sun, animated
- Publications — papers in English, and the Japanese list
- Access — address and directions
Prospective students
Undergraduate lab assignment follows the department's rules, and entry to the graduate school is decided by the entrance examination; for dates and procedures, follow the university's announcements. How the lab is run day to day is described on the How the lab works page, which also carries the address for visits and enquiries. To see what we work on, start with Research and People.
If you are enrolled at a university or graduate school outside Japan, see the exchange programs on NITech's Student Exchange Program page. Applications are often due around five months before the intended start, so please contact the lab as early as possible if you hope to be hosted here through one of them.
Photos and media: photographs of our equipment and experimental environments are on the Facilities page. Lab activities are posted on our external album (in Japanese).
News
-
Four new students, Genki, Yuto, Yoshihito, and Haruto, have joined the lab.
-
Keisuke gave a talk at RSJ2026.
-
Our joint research project with Osaka University, “Development of an omnidirectional, endlessly rotating mechanism free of singular configurations based on geometric power transmission,” was selected for NEDO’s Young Researcher Support Program (joint research formation track).
-
Yuki gave a talk at ASCC 2026.
-
The lab was awarded a laboratory infrastructure grant (electrical and electronic engineering) by the Murata Science and Education Foundation.
-
A group photo of lab members is now on the home page and in the sidebar.
-
Yuki’s paper has been accepted to ASCC 2026.
-
The lab website is now public. Publications, members, and news will be updated here.